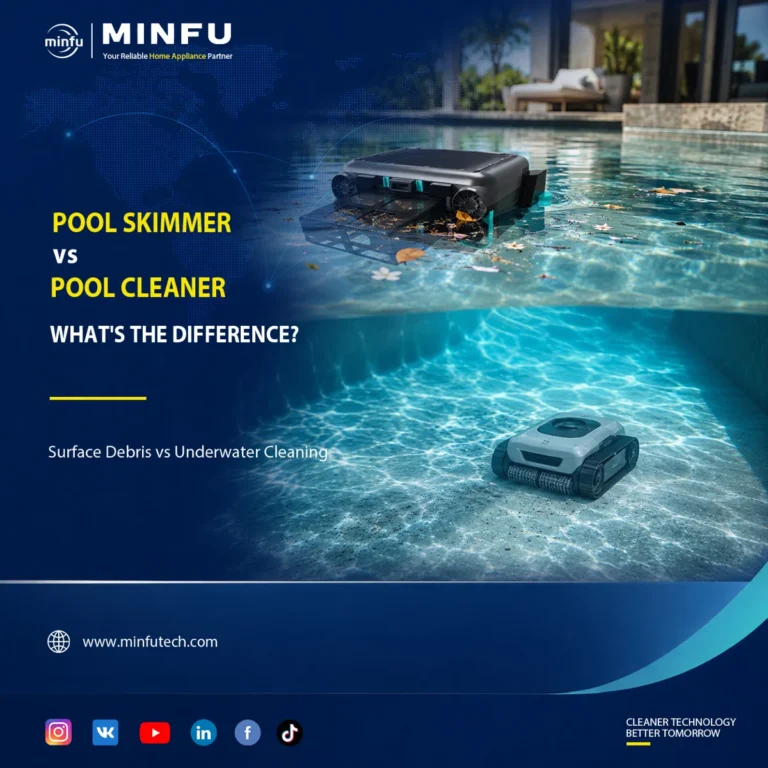



A robotic pool skimmer can have enough battery to work from morning until late evening and still deliver a poor autonomous cleaning experience.
Consider a fairly ordinary residential pool. The skimmer is placed in the water at 9 a.m. with a full battery and an empty filter. By noon, it is still running, so nothing appears wrong from a specification point of view. The problem is that it has spent part of the morning repeatedly approaching the same stainless-steel ladder, pushing against one rail, reversing, drifting back with the water current and trying the same area again.
The battery is working. The motors are working. The robot has not technically stopped.
Yet a meaningful part of its available runtime has produced very little useful surface cleaning.
This is why “anti-stuck” deserves more attention than the phrase usually receives on a product page. For a robotic pool skimmer, good autonomous performance is not defined by avoiding every obstacle without contact. Residential pools are too varied for that to be a realistic standard. What matters is whether the machine can spend most of its operating time collecting debris without repeatedly becoming trapped, grounded or caught in unproductive movement patterns that require the owner to intervene.
For importers, that behavior needs to be tested in the pool rather than assumed from the words anti-stuck design.
Why Robotic Pool Skimmers Get Stuck in the First Place
A surface skimmer operates in a mechanically awkward part of the swimming pool: directly at the boundary between air and water.
Unlike an underwater robotic cleaner that maintains contact with the pool floor, a surface robot depends on buoyancy and propulsion while wind and circulating water are constantly acting on its body. The machine may be moving forward under motor power while a return jet pushes it sideways and a light breeze slowly rotates its heading. Add a partially loaded filter and the floating balance can change again.
The pool itself makes the problem harder. Many of the objects a skimmer encounters are concentrated around the waterline, exactly where the robot needs to operate. Ladder rails pass vertically through the surface. Steps can sit only a few centimeters below it. Curved walls change the contact angle as the robot approaches. Floating hoses move with the water instead of remaining in one predictable position.
Debris creates another complication. Leaves are rarely distributed evenly across a pool. Wind and circulation often push them toward an edge or corner, so the area with the highest cleaning value may also be one of the more difficult areas for a floating robot to navigate.
That combination explains why watching a skimmer cruise through the middle of an empty rectangular pool tells buyers relatively little about anti-stuck performance. Open water is the easiest part of its job.
The interesting behavior begins near the edge.
The Hardest Part of the Pool Is Often Where the Debris Collects
Pool edges create a trade-off that is easy to miss during a short demonstration.
If a robot stays well away from walls, it reduces the chance of physical contact but may leave floating leaves concentrated along the perimeter. If it works very close to the edge, it has a better chance of collecting those leaves but will encounter walls, corners, ladders and shallow structures more frequently.
Current premium products show how seriously manufacturers treat this problem. Maytronics’ current Skimmi range uses infrared sensing above and below the waterline and offers settings related to edge cleaning and obstacle handling. Its support guidance even includes specific settings for pools where debris accumulates around the perimeter and for avoiding pool-cleaner hoses and cables.
For buyers evaluating another platform, those features are useful market references, but they should not become assumptions about every skimmer.
A ladder is a good example. The robot may encounter one rail head-on and recover immediately, then approach the same ladder from a shallow angle ten minutes later and behave very differently. A shallow step can create another situation in which most of the machine is still floating while one part of the underside begins to contact a solid surface.
Corners are particularly revealing because water movement often concentrates leaves there. The robot has to get close enough to collect useful debris without spending excessive time pushing into the intersection of two walls.
A good sample trial should therefore let the environment remain slightly inconvenient. Do not spread all the leaves neatly through open water simply because that creates a clean demonstration video. Allow some of them to gather beside a wall or near a step, then watch what the robot does when cleaning and navigation demands begin competing with each other.

A Moving Hose Is Harder to Predict Than a Wall
A pool wall has one useful characteristic: it stays where it is.
A floating hose does not.
A vacuum hose or another pool-cleaning cable can drift as circulation changes, move when the skimmer contacts it and end up in a completely different position later in the day. The robot may approach it from above, push it toward a wall, partly pass over it or catch the hose against part of its intake structure.
This makes a floating hose a useful test even when the product is primarily designed around physical anti-stuck features rather than sophisticated obstacle sensing.
It also highlights an important distinction between product capability and operating instructions. A manufacturer does not necessarily need to claim that a skimmer can intelligently recognize every flexible object in a swimming pool. If the safest and most reliable operating condition is to remove loose hoses before long autonomous operation, that can simply be stated clearly in the manual.
There is nothing unprofessional about acknowledging normal operating limits. The larger problem is promising “complete obstacle avoidance” and allowing the customer to discover those limits after purchase.
Premium sensor-based products are pushing the category further. Beatbot currently describes the iSkim Ultra as using 20 high-precision sensors, including ultrasonic sensing, together with path planning and obstacle/entanglement handling. That is a different engineering approach from a product whose anti-stuck strategy is primarily physical.
For sourcing teams, the distinction matters because those two architectures should not be marketed with the same language.
A Robot Can Waste Time Without Ever Becoming Physically Stuck
This is probably the most important issue to look for during a long test.
Imagine a robot approaching a strong return jet. The current pushes the front of the machine away from the wall, the robot corrects its heading, moves forward again and eventually escapes. Nothing requires human intervention.
Ten minutes later, it returns.
The same sequence happens again.
Technically, the robot never became stuck.
From a cleaning-efficiency perspective, however, it may be spending far too much time correcting itself in one small area.
The same pattern can occur around corners and ladders. A machine may repeatedly touch the same obstacle, reverse successfully and continue. Every individual recovery looks acceptable when viewed in isolation, but an overhead recording of several hours can reveal that a surprising amount of the operating window is being spent repeating the same movement.
This is where navigation connects directly with runtime.
In the previous article on robotic pool skimmer runtime, we looked at why a long battery specification should be interpreted as useful operating availability rather than simply hours on a stopwatch. A skimmer that can remain powered for fifteen hours still needs to use those hours productively.
For an importer, I would therefore separate two ideas:
Physical stuck event: the machine cannot free itself and needs human help.
Functional stuck behavior: the machine remains mobile but repeatedly wastes time in one area.
The second is much easier to miss during sample approval.
It may also be more common in day-to-day ownership because the customer does not necessarily see one dramatic failure. They simply notice that leaves remain untouched in another part of the pool despite the robot having been switched on all afternoon.

Physical Anti-Stuck Design and Sensor-Based Obstacle Avoidance Solve the Problem Differently
Once the problem本身 becomes clear, it is easier to compare different engineering approaches.
A physical anti-stuck design tries to make contact less likely to become a permanent trap. Body geometry, buoyancy distribution, protective foam, brackets and the shape of the intake can all influence what happens when the machine reaches a wall, shallow structure or another object.
Sensor-based obstacle avoidance attempts to identify obstacles more actively. Depending on the product, infrared or ultrasonic sensing may help the control system change course before or during an encounter. Software can also influence how the robot searches the surface and responds to repeated contact.
Neither term should be used casually.
Minfu’s current MFS01 product page describes physical anti-stuck foam and lists an anti-grounding bracket among the supplied accessories. The same page does not currently publish infrared, ultrasonic or similar proactive obstacle-detection hardware for MFS01.
That means an OEM version based on the current published platform should not automatically be promoted as using “AI obstacle avoidance,” “intelligent obstacle detection” or similar wording unless the exact final configuration actually includes and verifies those capabilities.
The more accurate question is whether the physical solution works well enough for the price and use case the buyer is targeting.
A relatively simple architecture can still create a good product if it deals reliably with ordinary residential pool features and rarely requires intervention. Conversely, adding a long sensor list does not guarantee good coverage if the software or mechanical design performs poorly in the conditions customers actually encounter.
Complexity is not the objective.
Useful unattended cleaning is.
Empty-Filter Testing Is Not Enough
Another reason anti-stuck behavior should not be approved during the first ten minutes of a demonstration is that the robot’s condition changes during cleaning.
MFS01 currently uses a 6L removable filter system, and the previous article on robotic pool skimmer filter capacity examined why wet leaves and mixed debris do not behave like an empty filter bag.
Once the machine has collected a meaningful amount of wet organic material, the mass inside the product and the way that material is distributed may differ from the starting condition. There is no reason to assume this automatically creates a navigation problem, but there is also little reason to leave it untested.
After the robot has collected a realistic amount of wet leaves, repeat the most difficult interactions.
Send it toward the ladder again. Let it work near the shallow step. Observe what happens in the same corner that caused repeated corrections earlier.
The comparison is more valuable than trying to calculate a theoretical effect from the filter weight. What matters is whether the actual sample behaves materially differently once it has been working for several hours.
This type of cross-testing also makes the whole content cluster more useful. Runtime, filter capacity and anti-stuck behavior are not isolated features in the real product. The customer experiences all of them at the same time.
A skimmer can be carrying wet debris, operating at a lower battery state and fighting a return-jet current while approaching a ladder.
That is a much more realistic product condition than the pristine sample floating through the center of a showroom pool.
How I Would Test a Robotic Pool Skimmer That Claims to Resist Getting Stuck
The test does not need to become an elaborate obstacle course.
In fact, deliberately unrealistic obstacles can make the results less useful because they tell the buyer how the robot handles a laboratory challenge rather than a residential pool.
I would start with the ordinary environment the target customer is most likely to own. Let the machine operate normally for long enough to establish its baseline behavior, then focus on the areas where real interaction occurs: perimeter walls, one ladder, one shallow step or ledge, a return jet and a floating hose when that type of object is common in the intended use case.
The important part is repetition.
A robot escaping a ladder once proves very little. Ten or twenty approaches from slightly different angles begin to reveal whether the behavior is dependable. The same trial should later be repeated with a realistic wet filter load.
An overhead camera is valuable because nobody needs to stand beside the pool watching for six hours. More importantly, recorded footage allows the sourcing team to review patterns that are difficult to recognize in real time.
Instead of recording only “pass” or “fail,” I would collect a few practical observations:
| What to Record | Why It Matters |
|---|---|
| Human rescue events | Shows true failures to self-recover |
| Long obstacle interactions | Reveals time lost even when eventual recovery succeeds |
| Repeated visits to the same trouble area | Helps identify functional sticking or inefficient coverage |
| Edge/corner debris left behind | Checks whether avoiding obstacles is reducing cleaning value |
| Behavior with a loaded filter | Shows whether real operating condition changes recovery |
| Physical wear after repeated contact | Checks whether brackets, foam or contact surfaces remain secure |
This is enough to turn “anti-stuck” from a marketing adjective into something the project team can actually discuss.
There is no need to demand perfection. The target should be a product that handles the expected environment with a reasonably low need for manual rescue and without sacrificing too much useful surface coverage.
Where MFS01 Fits
The current MFS01 platform is positioned as a dedicated solar-powered robotic pool skimmer rather than a premium sensor-heavy navigation platform. Minfu publishes a physical anti-stuck design based on anti-stuck foam and supplies an anti-grounding bracket with the product. It also lists a 2.8 kg body, 6L filtration system, 15+ hours of battery-only operation and remote-control capability.
Those features give a buyer a reasonable starting point for a practical obstacle test.
The physical components should first be inspected to understand where and how they are intended to interact with common pool structures. The sample can then be tested repeatedly around the type of ladders, steps and edges likely to appear in the destination market.
Because the current public specification does not state infrared or ultrasonic obstacle-detection hardware, marketing language should stay aligned with the verified physical design. If an OEM project introduces a different navigation configuration later, that version can be tested and described on its own evidence.
There is also value in testing remote control separately. Manual steering is useful when the customer wants to guide the skimmer toward a visible pile of leaves or recover it from an unusual situation, but the remote should not become the normal solution to routine obstacle problems.
A product marketed for autonomous surface maintenance should normally be able to spend most of its day working without asking the owner to rescue it.
That is a more meaningful standard than claiming that it “never gets stuck.”
Final Thoughts
A robotic pool skimmer does not have to move through a swimming pool without ever touching a wall, ladder or hose. The real measure of autonomy is what happens after those encounters and how much useful cleaning the robot completes between them.
This is why the easiest anti-stuck demonstration is often the least informative one. An empty rectangular pool removes many of the conditions that make surface navigation difficult: perimeter debris, return currents, shallow structures and moving obstacles.
A better sample test keeps those ordinary complications in place and watches the robot for long enough that repeated behavior becomes visible.
For buyers, the difference between physically stuck and functionally stuck is particularly important. One stops the robot completely. The other quietly wastes runtime while the machine remains technically operational.
Both affect the ownership experience.
The objective is not to find the robot with the longest list of sensors or the strongest marketing claim. It is to source a product that can spend most of its operating window doing what the customer bought it to do: collecting floating debris with minimal intervention.
That is the standard an anti-stuck feature should ultimately be judged against.
Frequently Asked Questions
Why do robotic pool skimmers get stuck?
Robotic pool skimmers operate directly at the water surface, where wind, water circulation, ladders, shallow steps, pool edges and floating objects can all affect movement. A robot may become physically trapped, partially grounded or caught in repeated navigation behavior even though its motors continue running.
Can a robotic pool skimmer get stuck on a pool ladder?
Yes, depending on the ladder geometry and the robot’s design. Ladder rails intersect the waterline and can create different contact situations depending on the approach angle. Buyers should test repeated approaches rather than judging performance from one successful escape.
What is the difference between anti-stuck design and obstacle avoidance?
Anti-stuck design can include physical structures intended to reduce grounding or help the robot recover after contact. Obstacle avoidance usually implies sensing and control systems that detect or react to obstacles. The exact technology should be verified for the specific product rather than inferred from marketing terminology.
Can pool hoses interfere with robotic skimmers?
They can. Unlike a fixed wall, floating hoses and cables move with the water and may change position after contact. Some advanced skimmers include dedicated hose-avoidance functions, while other products may require the operating area to be prepared before long autonomous cleaning.
Does a full filter affect robotic pool skimmer navigation?
A wet debris load changes the operating condition of the robot, so buyers should repeat obstacle tests with a realistically loaded filter. The actual effect should be measured on the sample rather than assumed from the nominal filter capacity.
Does MFS01 use intelligent obstacle-avoidance sensors?
Minfu’s current public MFS01 specification lists physical anti-stuck foam and an anti-grounding bracket, but it does not currently publish infrared, ultrasonic or similar proactive obstacle-detection sensors. Stronger sensor-based claims should therefore be verified against the exact OEM configuration before use.
Ready to Start Your OEM/ODM Project?
Whether you are sourcing a new product, developing a private-label line, or looking for a reliable OEM/ODM manufacturing partner, Minfu can support your project from product evaluation and customization to packaging, production and long-term cooperation.
Shenzhen Minfutech Industrial Co., Ltd.
Website:
https://minfutech.com/
Email:
info@minfutech.com
WhatsApp / Tel:
+86 137 6025 5781
Contact Us:
https://minfutech.com/contact-minfu/
OEM / ODM • Private Label • Product Customization • Wholesale
Send us your sourcing requirements, target market and project details. Our team will help you evaluate the suitable solution and discuss the next steps for your OEM/ODM project.